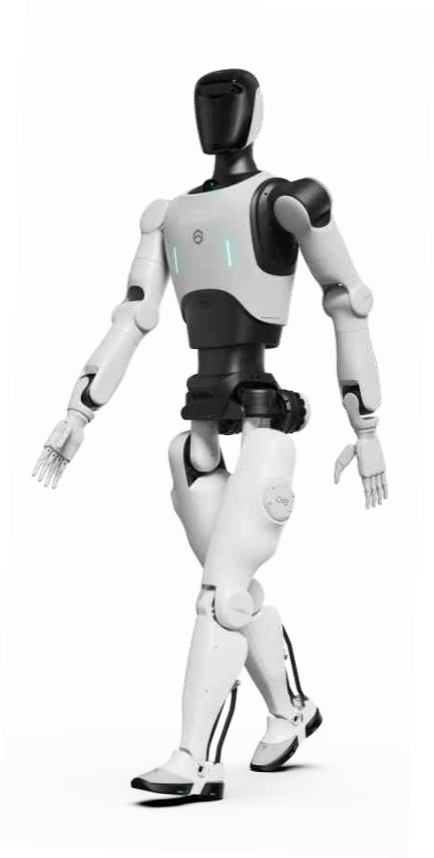

A full-size intelligent humanoid robot, featuring high integration, high reliability, and high computing power.
Equipped with 3D LiDAR, depth cameras, a circular microphone array, a high-resolution facial display, and other perception and interaction devices, it can achieve intelligent perception, interaction, and decision-making by integrating AI large models, meeting emotional interaction needs.
It can be applied in public safety and commercial service fields such as reception, guided tours, and automotive sales, and can also serve as a skilled worker in industrial processes such as logistics handling, material picking, and appearance inspection.
Core Parameters
3D LiDAR
Hybrid solid-state laser, 360-degree stereoscopic perception
High-resolution curved LCD screen
Dynamic human-robot interaction, rich emotional communication
Arm degrees of freedom 7*2
Reaches any position in the workspace, offering greater flexibility
Depth stereo cameras*2
Multi-layer distributed stereoscopic perception for navigation and obstacle avoidance
High-performance integrated joints
Comprehensively enhanced safety and stability, maximum joint torque up to 300Nm
Dexterous hand degrees of freedom 12*2
Equipped with 5-finger dexterous hands, enabling multiple grasping modes and fine manipulation
Feet
Multi-degree-of-freedom force control, adaptive to uneven terrain
Leg degrees of freedom 6*2
Enables complex motion execution such as walking, running, slopes, and stairs
| Height dimensions | Self-weight (including battery) | Battery life | Walking speed | Maximum speed |
| 175cm | 65kg | 2h | ≤2km/h | ≥6km/h |
| Dual-arm payload | Working radius | Degrees of freedom | Obstacle avoidance method | Navigation method |
| 20kg | 750mm | 42 | Laser/Vision | LiDAR-vision fusion |
| Emergency stop button | Audible and visual alarm | Communication method | ||
| Equipped | Equipped | EtherCAT/WIFI/5G |
Note: All parameters are official test data. Deviations may occur under actual operating conditions. Secondary development is supported.