NVIDIA Upgrades Robotics Development Platform with Over 2,000 New Simulation Assets
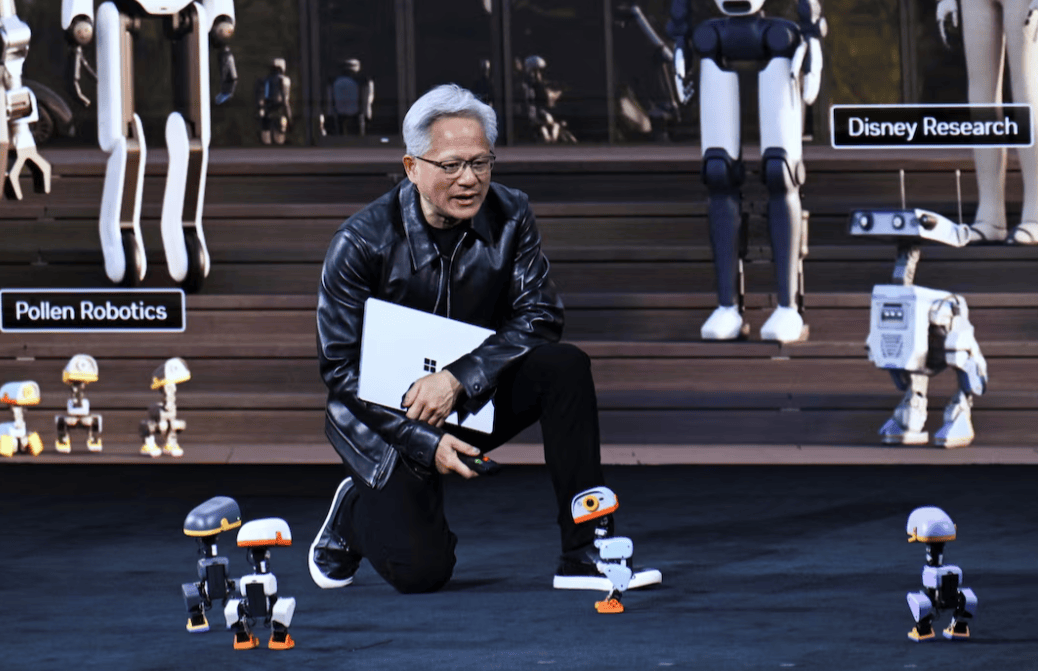
en.Wedoany.com Reported - On October 21, NVIDIA announced at the GTC conference held in Berlin, Germany, the expansion of its Isaac open robotics development platform, introducing the Isaac OS robot runtime framework, officially releasing Isaac Lab 3.0, and adding more than 2,000 robot and factory assets that can be directly used for simulation. The update also includes the Agile ONE SN humanoid robot reference platform and three open-source training workflows, covering R&D stages such as robot data generation, physics simulation, model training, and real-world deployment.
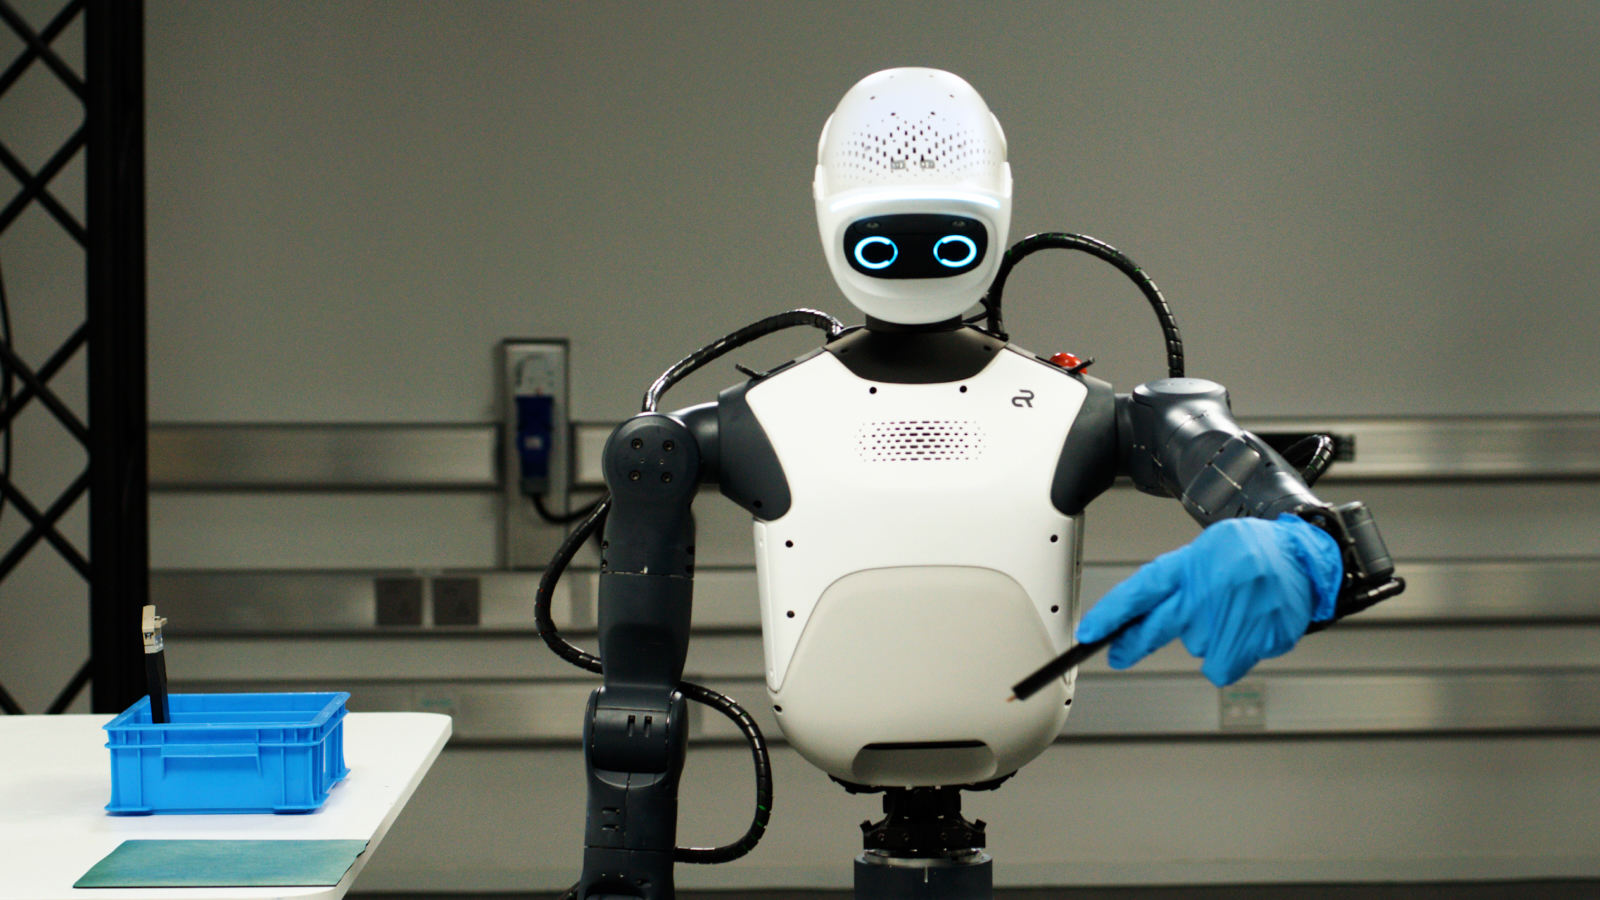
The newly released Isaac Lab 3.0 is now officially available, enabling developers to train and optimize robot control policies using multi-GPU computing resources, and is compatible with the Newton and PhysX physics engines. The newly launched Isaac OS is built on Holoscan and is responsible for connecting AI models, sensors, control systems, and robot hardware, supporting real-time control program deployment from simulation environments to physical robots. NVIDIA also provides three open-source reference workflows for DGX Station, respectively for GR00T 1.7 model reinforcement learning, dexterous manipulation skill training, and generating synthetic training data via the Cosmos world model.
Training data resources have also been expanded. The SimReady Central Library contains more than 2,000 simulation assets for robots, industrial equipment, and factory environments, covering industrial robotic arms, manipulators, and manufacturing facilities. The newly introduced Human 1M dataset includes synchronized three-view videos and 3D hand tracking data of various human activities, which can be used for robot motion learning and manipulation policy development. The related resources are available through the Hugging Face platform, with the complete Human 1M dataset open to Cosmos Coalition partners.
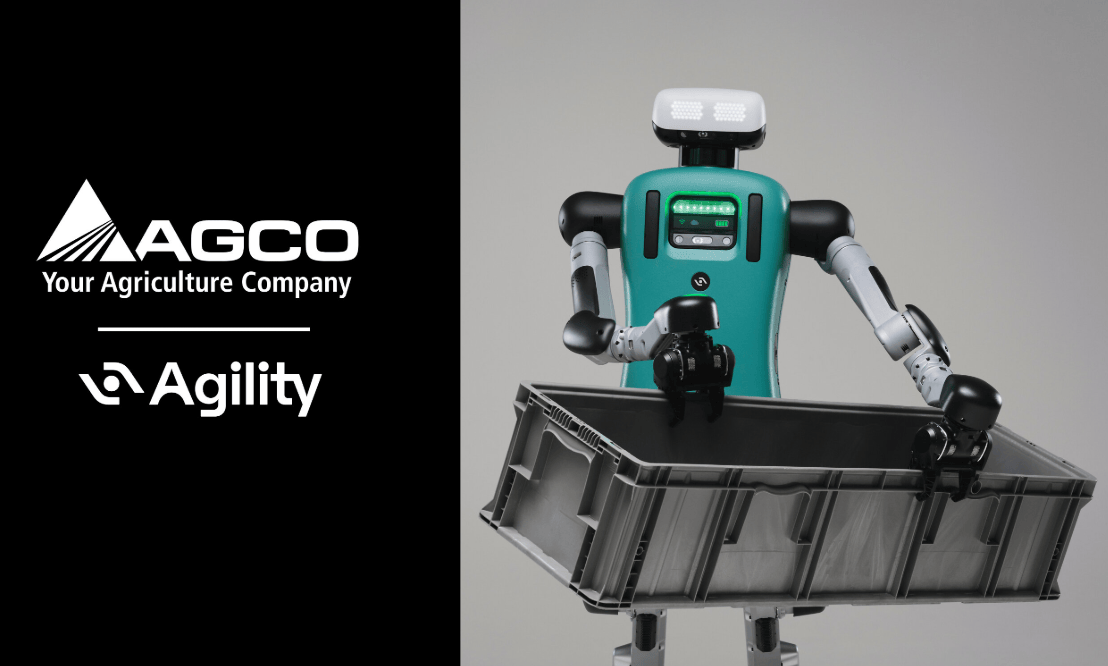
Released alongside the software update, the Agile ONE SN was developed by Agile Robots and adopts a humanoid robot body with a height of 1.40 meters and a weight of 40 kilograms, featuring 31 body degrees of freedom and a single-arm payload of 3 kilograms. The robot is equipped with two WUJI Hand 2 five-fingered dexterous hands, each with 20 degrees of freedom, and an actuation system supporting 1 kHz force control and tactile sensing. The onboard Jetson Thor computing platform provides 2070 FP4 TFLOPS of computing power and 128 GB of unified memory, and the complete system also integrates head and wrist cameras, LiDAR, and an inertial measurement unit. The reference platform is planned for launch in early 2027 for robotics research institutions to conduct motion training, system integration, and performance validation.
European robot manufacturers have already begun adopting some of the technologies released this time. ABB Robotics is integrating NVIDIA Omniverse tools into RobotStudio HyperReality for robot system simulation and virtual commissioning; KUKA is using the related tools for the FactoryLens factory simulation environment. NEURA Robotics is using Isaac Sim and Isaac Lab to generate synthetic training data and train robot skills; Humanoid is adopting Jetson Thor, Isaac OS, and Halos safety technology to develop and validate robot behaviors before industrial pilots.
Related Products

Tactical Individual Carrying Handcart Platform
Automation Research Institute Co., Ltd. of China South Industries Group Corporation
CLX Series Intelligent Hydraulic Gyratory Crusher
Guangdong CHUANGLI intelligent machinery Equipment Co., LTD
QLZNGJ Intelligent Steel Reinforcement Trolley
Luoyang China Railway Qiangli Machinery Co., Ltd.
Pallet Solutions Product Line: HD3000 Double-Column Stacker Crane
Zhongding Intelligent (Wuxi) Technology Co., Ltd.
Industrial and Commercial Point-Type Gas Detector
Jinan Benan Technology Development Co., Ltd.